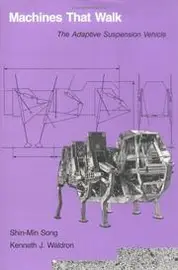
Machines that walk
Shin-Min Song, Kenneth J. Waldron · 1988
Minds, machines and the future › Cybernetics and complex systems
#12,795 most recommended
Hacker News
2
mentions by 2 people · top 79% of 15,732 books
Open Library
—
No ratings yet
Wikipedia
—
No article yet
About the book
The subject is legged walking machines, centred on the Adaptive Suspension Vehicle, a six-legged robot developed at Ohio State University's locomotion laboratory. It covers the mechanical design, leg and body kinematics, gait planning and control of such machines, within the wider fields of robotics and automated production. The central claim is that walking machines can cross terrain that defeats wheeled and tracked vehicles, if the mechanism, the suspension and the control system are designed together. The adaptive suspension lets each leg respond to uneven ground so the body stays level and the vehicle keeps its footing. The authors present the Adaptive Suspension Vehicle as a working demonstration of this approach, not only as a theoretical proposal.
Written by Claude from what it knows of this book.
What Hacker News says 0% recommend · 0% critical
In the commenters’ own words
There's an MIT Press book.[1] Chapter 6, "Leg Design by Four Bar Linkage Synthesis" covers the four-bar linkage. They were struggling to get enough working…
Some of these books are still around ih various forms, for example: https://www.amazon.com/Handbook-Artificial-Intelligence-Avro…
What Open Library readers say
No Open Library reader has rated it yet.
What critics say, via Wikipedia
No Wikipedia article about this book yet, so no critics to quote.
Reddit communities — coming later
Details
- First published
- 1988
- ISBN
- 9780262192743
- Editions known
- 6 at Open Library
- Open Library
- OL4624960W
Automatic machineryComputer Books: GeneralComputer ScienceComputersComputers / Computer ScienceHuman locomotionIndustrial RoboticsProduction engineeringRoboticsRobotsTechnology & Industrial Arts
Read next: its neighbours on the mosaic
 The connection machineW. Daniel Hillis · 1985 · recommended by 3 people · similar by subject and what people say about it
 RobotHans Moravec · 1998 · recommended by 2 people · similar by subject and what people say about it
 Machines of loving graceJohn Markoff · 2015 · recommended by 5 people · similar by subject and what people say about it
 507 Mechanical MovementsHenry T. Brown · 1991 · recommended by 3 people · similar by subject and what people say about it
 RoboticsBruno Siciliano · 2009 · recommended by 3 people · similar by subject and what people say about it
 Five hundred and seven mechanical movementsHenry T. Brown · 1868 · recommended by 1 person · loosely similar by subject
 The Dream MachineM. Mitchell Waldrop · 2001 · recommended by 109 people · loosely similar by subject
 LivewiredDavid Eagleman · 2020 · recommended by 4 people · loosely similar by subject
 The complete handbook of roboticsEdward L. Safford · 1978 · recommended by 1 person · loosely similar by subject
 The Computer and the BrainJohn Von Neumann · 1958 · recommended by 9 people · loosely similar by subject
 Cybernetics, or control and communication in the animal and the machineNorbert Wiener · 1948 · recommended by 4 people · loosely similar by subject
 Between Human and MachineDavid A. Mindell · 2002 · recommended by 6 people · loosely similar by subject
 Vehicles, experiments in synthetic psychologyValentino Braitenberg · 1984 · recommended by 10 people · loosely similar by subject
 Machine manMax Barry · 2011 · recommended by 5 people · loosely similar by subject
 Mind childrenHans Moravec · 1988 · recommended by 1 person · loosely similar by subject
 Darwin among the machinesGeorge Dyson · 1997 · recommended by 8 people · loosely similar by subject
 How the body shapes the way we thinkRolf Pfeifer · 2006 · recommended by 2 people · loosely similar by subject
 Probabilistic roboticsSebastian Thrun · 2005 · recommended by 26 people · loosely similar by subject
 Mind Over MachineHubert L. Dreyfus · 1986 · recommended by 3 people · loosely similar by subject
 Human-machine reconfigurationsLucille Alice Suchman · 2007 · recommended by 3 people · loosely similar by subject
 Mechanizing ProofDonald MacKenzie · 2001 · recommended by 1 person · loosely similar by subject
 The animator's survival kitRichard Williams · 2001 · recommended by 11 people · loosely similar by subject
 Human CompatibleStuart J. Russell · 2019 · recommended by 9 people · loosely similar by subject
 Rise of the RobotsMartin Ford · 2015 · recommended by 1 person · loosely similar by subject